builds
Building a 4-DOF Robotic Arm: TowerPro Servos, Inverse Kinematics & Joystick Control
Construct a 4-degree-of-freedom desktop robotic arm capable of precision pick-and-place maneuvers using TowerPro metal gear servos and analog dual-axis joysticks.
Kunal (Founder & Owner) 1 min read10 Oct 2026
Building a 4-DOF Robotic Arm: TowerPro Servos, Inverse Kinematics & Joystick Control
Robotic arms form the backbone of industrial automated manufacturing. This desktop 4-DOF (Degrees of Freedom) robotic manipulator features base rotation (yaw), shoulder flexion, elbow extension, and a mechanical end-effector gripper, controlled by twin analog joysticks.
1. System Anatomy
- Base Waist Servo (MG996R / MG90S): 0° to 180° horizontal panning
- Shoulder Joint Servo (MG996R): High-torque vertical elevation
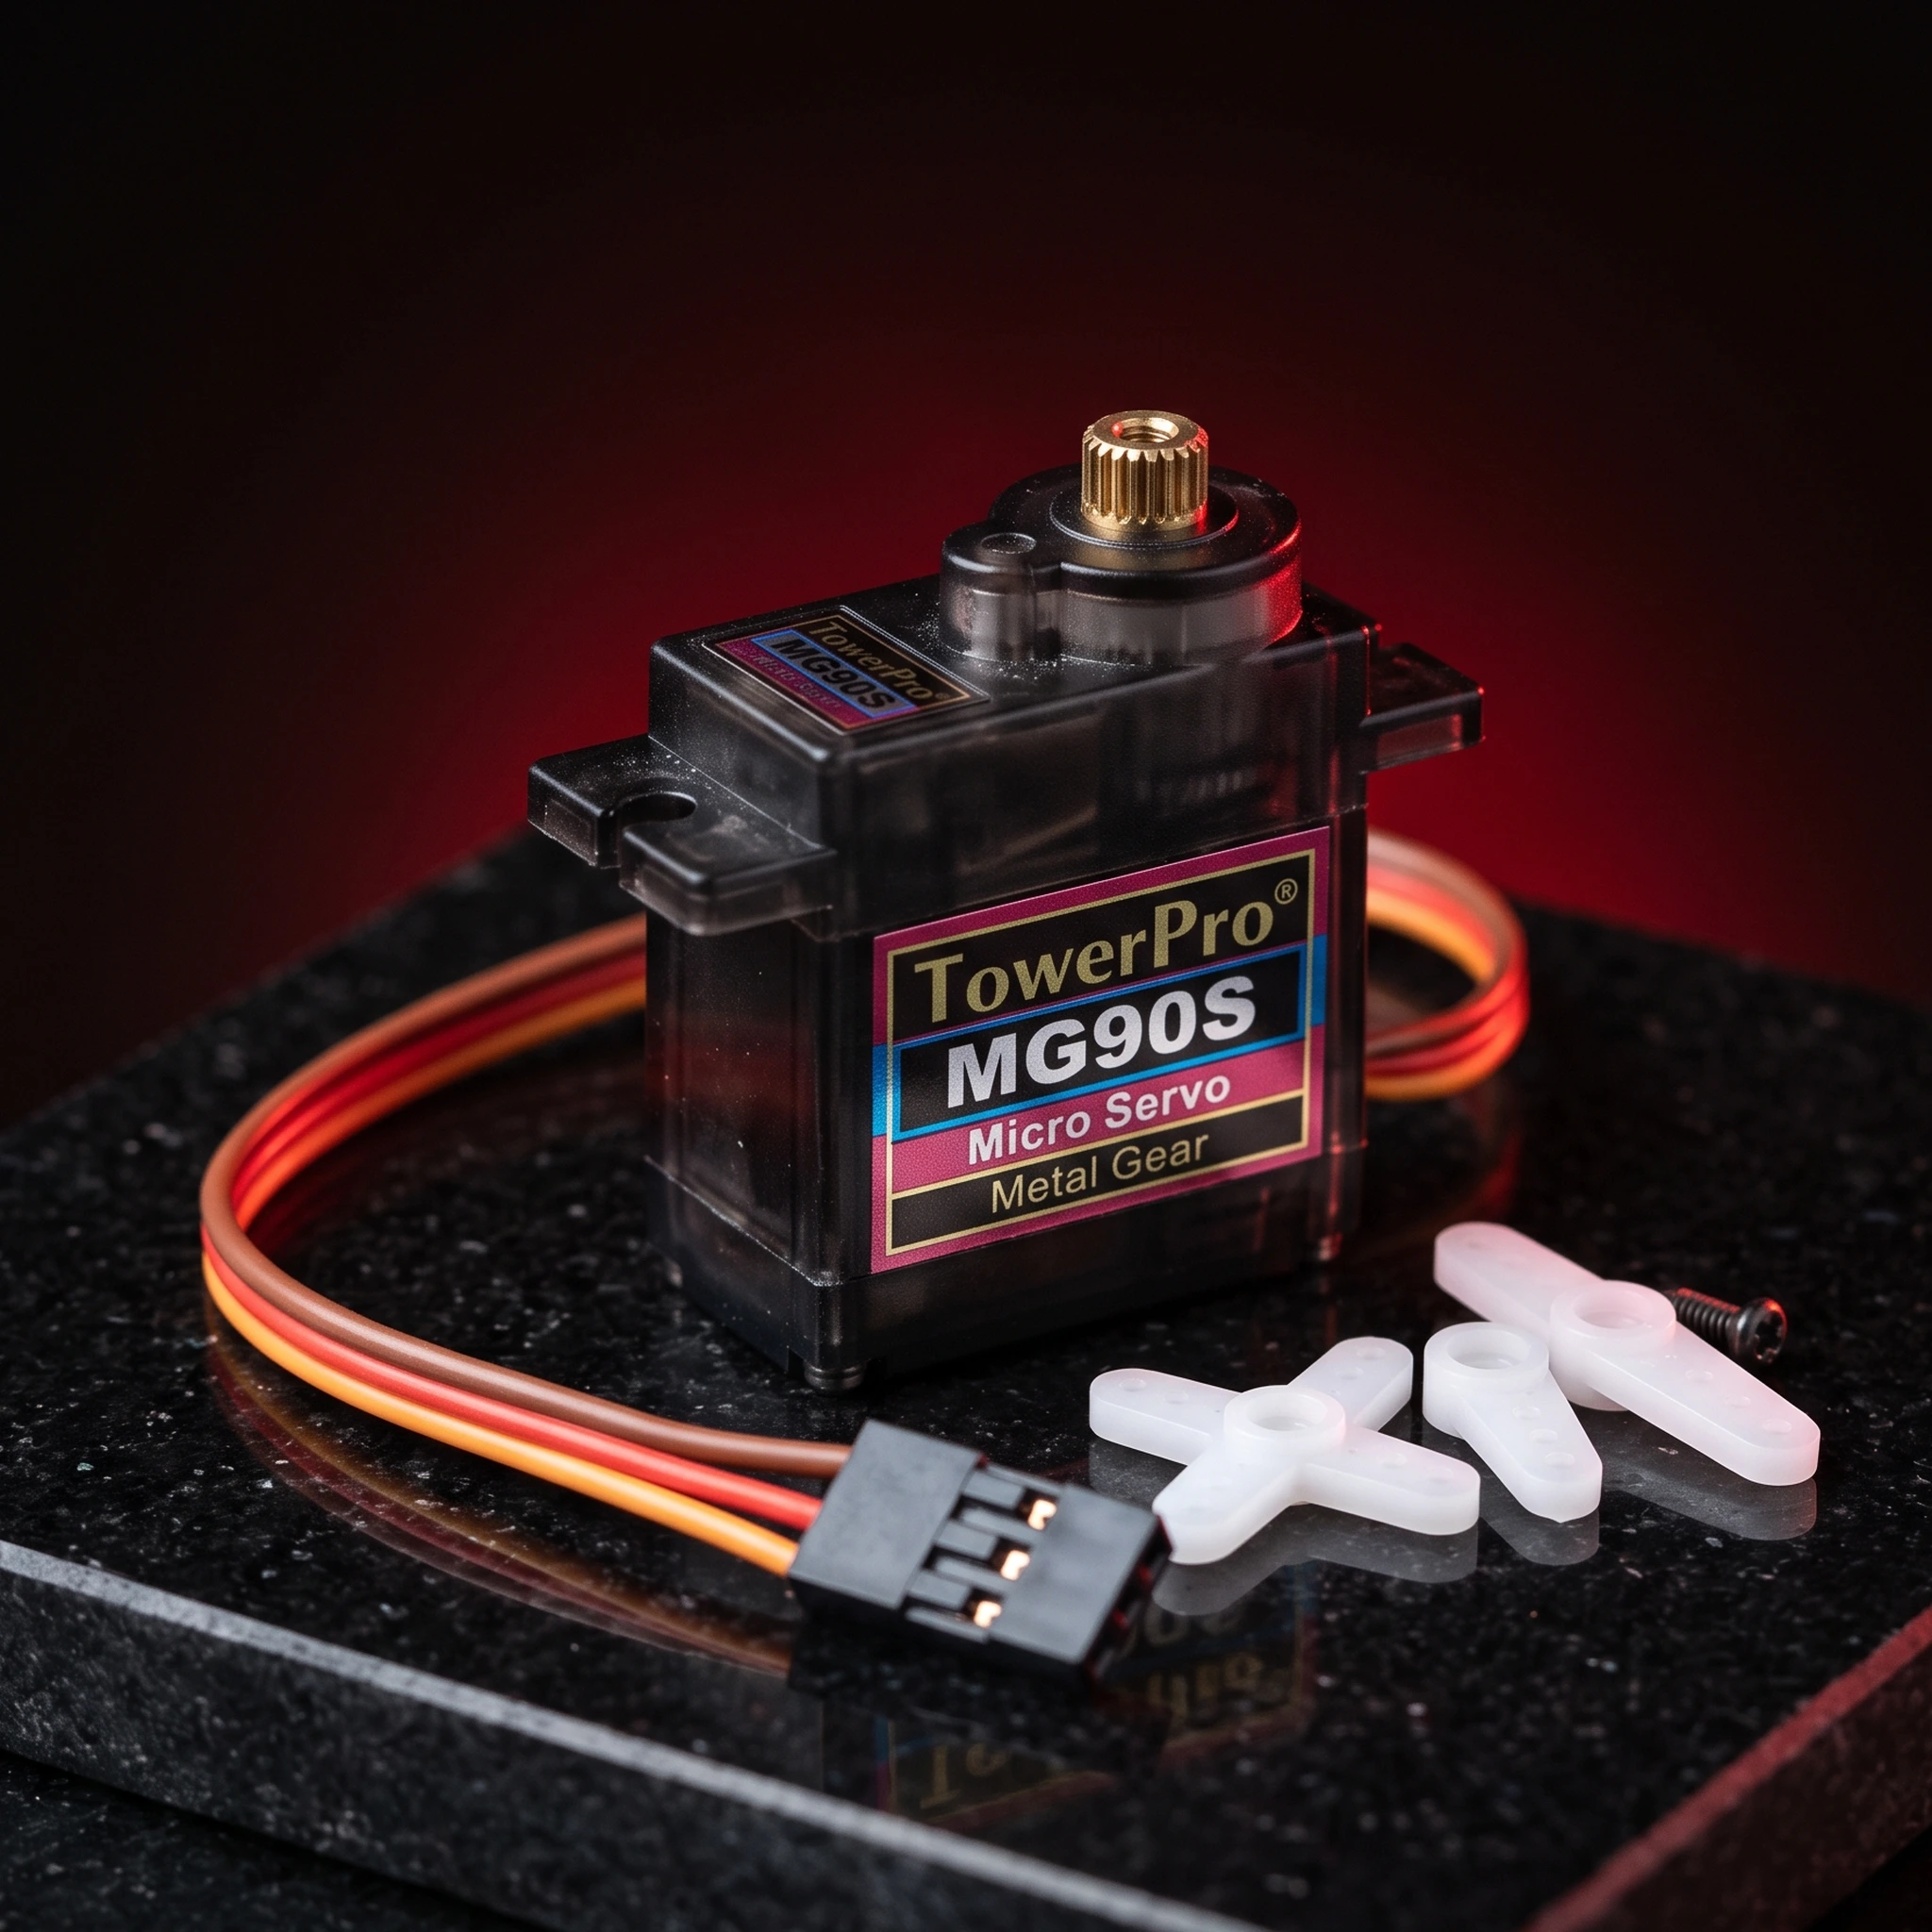
- Elbow Joint Servo (MG90S): Forward and backward reach
- End-Effector Gripper Servo (SG90): Claws open and close
- Controller: Arduino UNO with dedicated 5V 3A external servo supply rail
2. Wiring Schematic
Connect dual analog joystick potentiometers to Arduino inputs:
- Joystick 1 X-axis → Analog A0 (Base Yaw)
- Joystick 1 Y-axis → Analog A1 (Shoulder)
- Joystick 2 X-axis → Analog A2 (Elbow)
- Joystick 2 Y-axis → Analog A3 (Gripper Open/Close)
cpp#include <Servo.h>

Servo baseServo, shoulderServo, elbowServo, gripServo;

void setup() {
  baseServo.attach(3);
  shoulderServo.attach(5);
  elbowServo.attach(6);
  gripServo.attach(9);
}

void loop() {
  int x1 = analogRead(A0);
  int y1 = analogRead(A1);
  int x2 = analogRead(A2);
  int y2 = analogRead(A3);

  baseServo.write(map(x1, 0, 1023, 0, 180));
  shoulderServo.write(map(y1, 0, 1023, 15, 165));
  elbowServo.write(map(x2, 0, 1023, 10, 170));
  gripServo.write(map(y2, 0, 1023, 0, 90));

  delay(20);
}
Parts used in this tutorial
Buy them in one click — ships from Pune across India.
- Robotic Arm KitKits₹2,500.00+ GST
- TowerPro Metal Gear MG90S Mini Digital Servo Motor (180° Rotation)Motors & Actuators₹179.00+ GST
- Arduino UNOMicrocontrollers₹265.58+ GST
Approx. total ₹2,944.58 (before GST)Add all to cart
#robotics#servos#mechatronics
Found this useful? Tell us what you'd like to read next via our RFQ form.